
Skip to content
KitploitKITPLOIT
ToolsBlog
Log in
Submit
ToolsBlog
Submit

Hacking, PenTest, and Cybersecurity Tools for Your Security Arsenal!

Kitploit is a directory of hacking, cybersecurity, and pentesting tools. Discover the latest project updates to find vulnerabilities, analyze systems, automate testing, and strengthen your security.

··Feeds·Contact·Privacy·© 2026 Kitploit

Tool Directory

Categories

View all categories
Loading categories
Damn-Vulnerable-Drone — Damn Vulnerable Drone is an intentionally vulnerable drone hacking simulator based on the popular ArduPilot/MAVLink architecture, providing a realistic environment for hands-on drone hacking. | Kitploit
Tools/GitHubGitHub/nicholasaleks/damn-vulnerable-drone
ReconnaissanceWi-Fi AuditingIoT SecurityVulnerability AnalysisExploitationWireless SecurityPenetration TestingHardware & IoT SecurityLearning & Education

Most Popular

View all →

Discover the most used tools by our community.

Explore all tools

Browse our collection of tools

View all tools →
Share
Labs & Practice
GitHubnicholasaleks/damn-vulnerable-drone

Damn-Vulnerable-Drone

Damn Vulnerable Drone is an intentionally vulnerable drone hacking simulator based on the popular ArduPilot/MAVLink architecture, providing a realistic environment for hands-on drone hacking.

View Repository
772135331 day agoReviewed by Kitploit

Damn Vulnerable Drone

The Damn Vulnerable Drone is an intentionally vulnerable drone hacking simulator based on the popular ArduPilot/MAVLink architecture, providing a realistic environment for hands-on drone hacking.
Damn Vulnerable Drone Logo

Table of Contents

  • About the Damn Vulnerable Drone
    • What is the Damn Vulnerable Drone?
    • Why was it built?
    • How does it work?
    • Features
  • Installation
    • System Requirements
    • Getting Docker
    • Wi-Fi Mode
    • Non-Wi-Fi Mode
  • Architecture
  • Flight States
  • Attack Scenarios
  • Screenshots
  • Mentions
  • Community Support
  • Feedback & Contributions
  • Maintainers
  • Credits
  • Disclaimer
  • License

About the Damn Vulnerable Drone

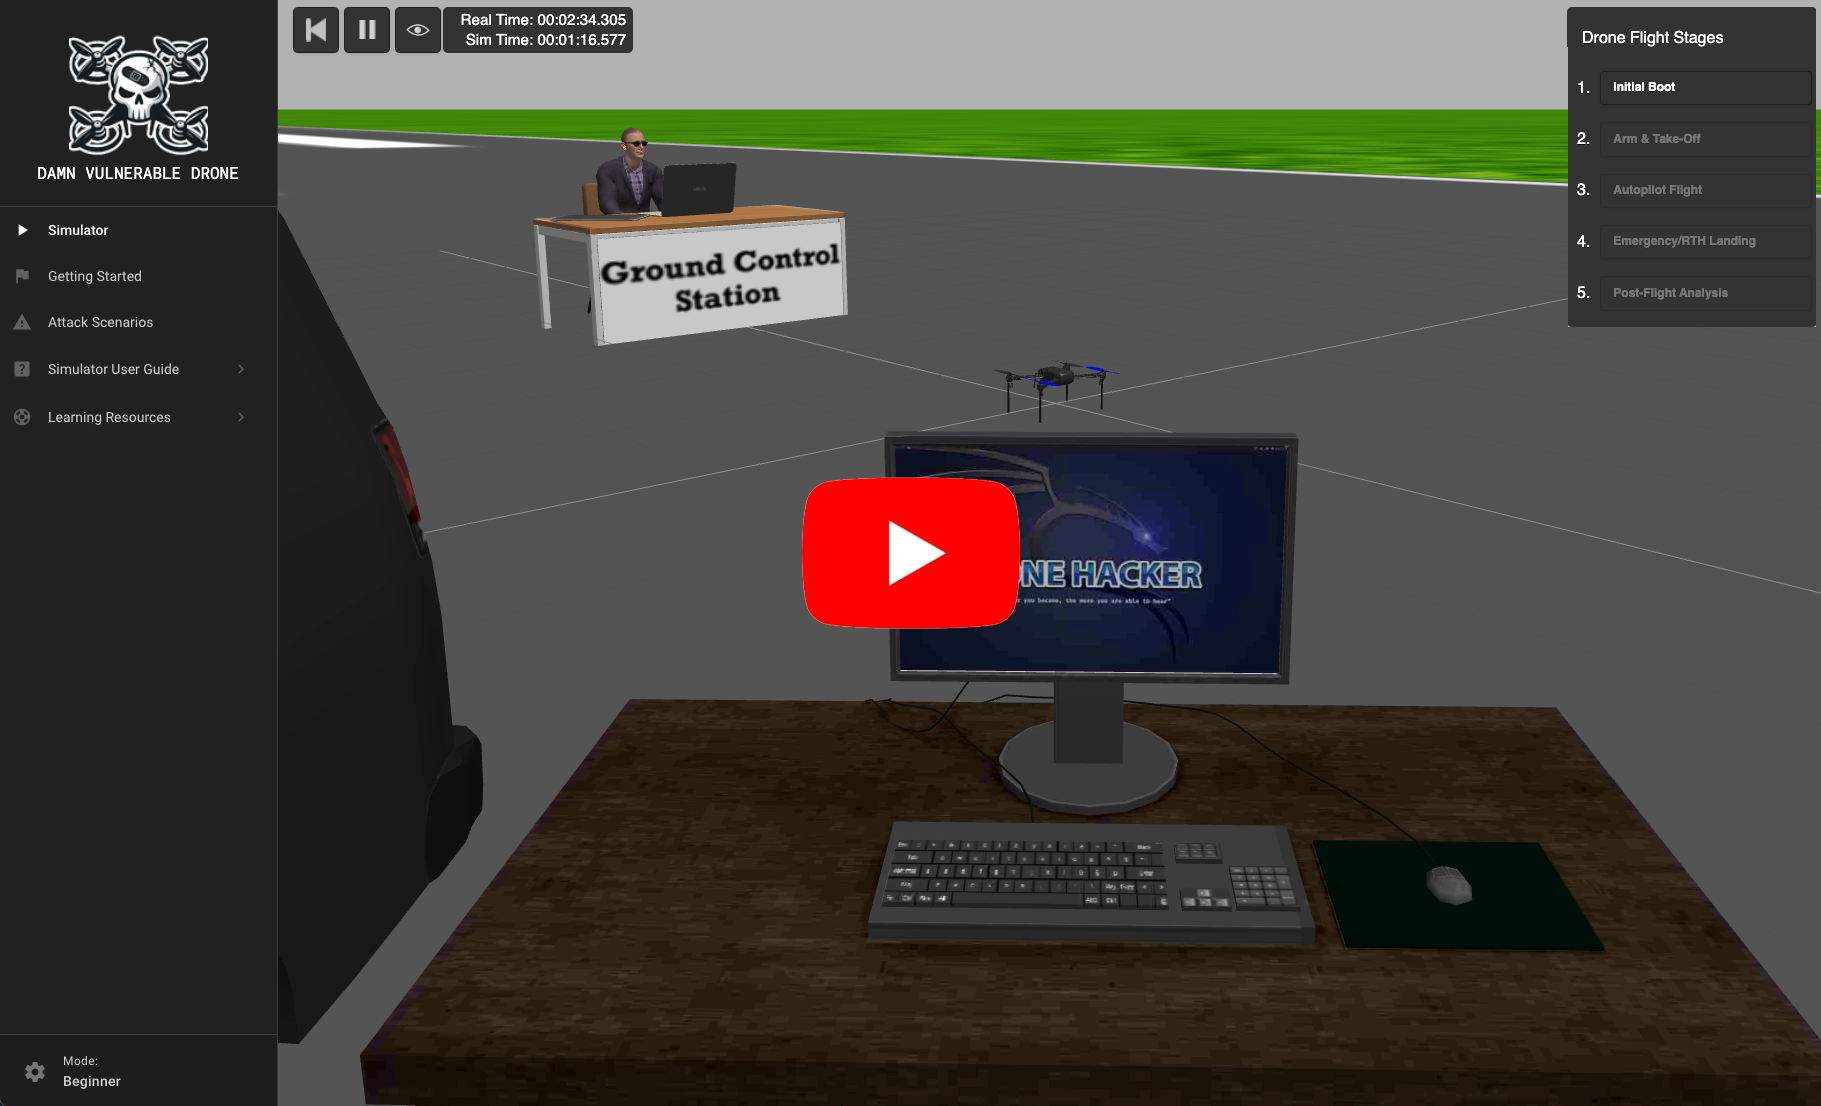
Damn Vulnerable Drone Demo

What is the Damn Vulnerable Drone?

The Damn Vulnerable Drone is a virtually simulated environment designed for offensive security professionals to safely learn and practice drone hacking techniques. It simulates real-world ArduPilot & MAVLink drone architectures and vulnerabilities, offering a hands-on experience in exploiting drone systems.

Why was it built?

The Damn Vulnerable Drone aims to enhance offensive security skills within a controlled environment, making it an invaluable tool for intermediate-level security professionals, pentesters, and hacking enthusiasts.

Similar to how pilots utilize flight simulators for training, we can use the Damn Vulnerable Drone simulator to gain in-depth knowledge of real-world drone systems, understand their vulnerabilities, and learn effective methods to exploit them.

The Damn Vulnerable Drone platform is open-source and available at no cost and was specifically designed to address the substantial expenses often linked with drone hardware, hacking tools, and maintenance. Its cost-free nature allows users to immerse themselves in drone hacking without financial concerns. This accessibility makes the Damn Vulnerable Drone a crucial resource for those in the fields of information security and penetration testing, promoting the development of offensive cybersecurity skills in a safe environment.

How does it work?

The Damn Vulnerable Drone platform operates on the principle of Software-in-the-Loop (SITL), a simulation technique that allows users to run drone software as if it were executing on an actual drone, thereby replicating authentic drone behaviors and responses.

ArduPilot's SITL allows for the execution of the drone's firmware within a virtual environment, mimicking the behavior of a real drone without the need for physical hardware. This simulation is further enhanced with Gazebo, a dynamic 3D robotics simulator, which provides a realistic environment and physics engine for the drone to interact with. Together, ArduPilot's SITL and Gazebo lay the foundation for a sophisticated and authentic drone simulation experience.

While the current Damn Vulnerable Drone setup doesn't mirror every drone architecture or configuration, the integrated tactics, techniques and scenarios are broadly applicable across various drone systems, models and communication protocols.

Features

  • Docker-based Environment: Runs in a completely virtualized docker-based setup, making it accessible and safe for drone hacking experimentation.
  • Simulated Wireless Networking: Simulated Wifi (802.11) interfaces to practice wireless drone attacks.
  • Onboard Camera Streaming & Gimbal: Simulated RTSP drone onboard camera stream with gimbal and companion computer integration.
  • Companion Computer Web Interface: Companion Computer configuration management via web interface and simulated serial connection to Flight Controller.
  • QGroundControl/MAVProxy Integration: One-click QGroundControl UI launching (only supported on x86 architecture) with MAVProxy GCS integration.
  • MAVLink Router Integration: Telemetry forwarding via MAVLink Router on the Companion Computer Web Interface.
  • Dynamic Flight Logging: Fully dynamic Ardupilot flight bin logs stored on a simulated SD Card.
  • Management Web Console: Simple to use simulator management web console used to trigger scenarios and drone flight states.
  • Comprehensive Hacking Scenarios: Ideal for practicing a wide range of drone hacking techniques, from basic reconnaissance to advanced exploitation.
  • Detailed Walkthroughs: If you need help hacking against a particular scenario you can leverage the detailed walkthrough documentation as a spoiler.

Installation

Please review the following instructions carefully to ensure a stable and well performing Damn Vulnerable Drone lab environment.

[!NOTE]
Depending on your computer’s performance and internet speed, the full end-to-end installation process including container builds and image pulls, can take between 30-60 minutes. Be patient and let each step complete before moving forward.

System Requirements

Damn Vulnerable Drone can be run in two modes depending on your available hardware:

Lite Mode (No GPU Required)

  • Operating System:

    • Kali Linux (recommended, but Lite mode may run on most Linux distros)
    • Works on bare metal or VM environments without GPU passthrough
  • Hardware (Minimum):

    • RAM: 4–8 GB
    • Processor Cores: 2
    • Disk Storage: 100 GB
    • Swap: 4 GB
  • Graphics:

    • No GPU required
    • Runs a 2D lightweight simulator using ArduPilot’s built-in flight dynamics model instead of Gazebo
  • Software:

    • Docker
    • Docker Compose

Lite Mode is recommended for users who cannot meet the GPU requirements of Full Mode or want a faster, more lightweight setup.
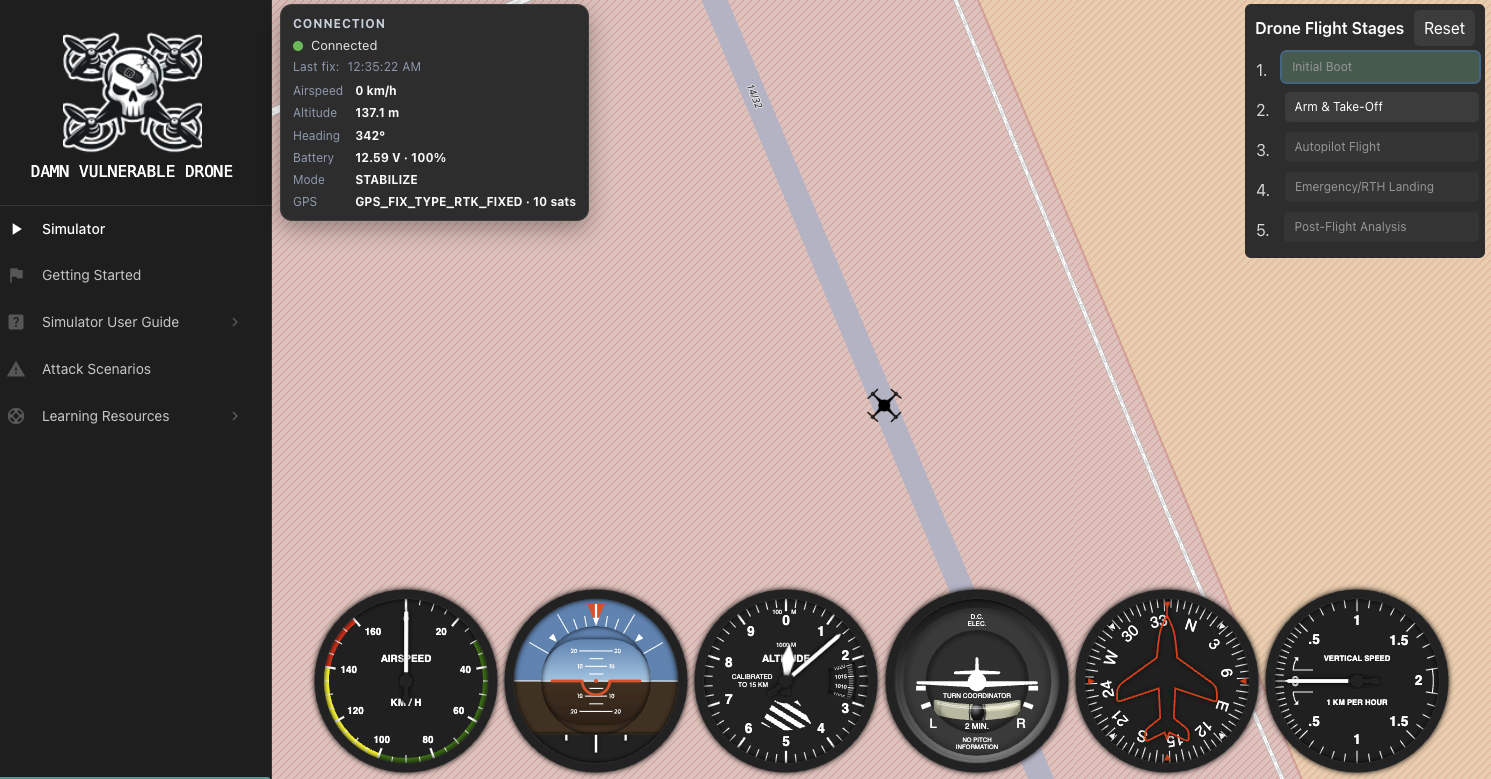
Lite Mode Interface

Damn Vulnerable Drone Lite Mode


Full Mode (3D Environment with Gazebo)

  • Operating System:

    • Kali Linux (no other OS is supported)
    • For best performance, use bare metal
    • If you must use a VM, ensure GPU passthrough is enabled
      • See this guide on Hyper-V GPU passthrough for setup help
  • Hardware (Minimum):

    • RAM: 8–16 GB
    • Processor Cores: 2–4
    • Disk Storage: 100 GB
    • Swap: 10–12 GB
  • Graphics:

    • At least 2 GB VRAM (4 GB+ recommended)
    • OpenGL 3.0 (or higher)
    • Dedicated GPU strongly recommended
    • For VMs: Enable GPU passthrough and 3D acceleration
  • Software:

    • Docker
    • Docker Compose

Full 3D Mode Interface

Damn Vulnerable Drone Full Mode


Getting Docker (Key Dependency)

Download Tool